Bomba Tespit ve Keşif Robotu
CompletedAn STM32-based reconnaissance rover driven from a phone over Bluetooth that stops on its own and raises an alarm when its inductive sensor detects metal objects.
Project
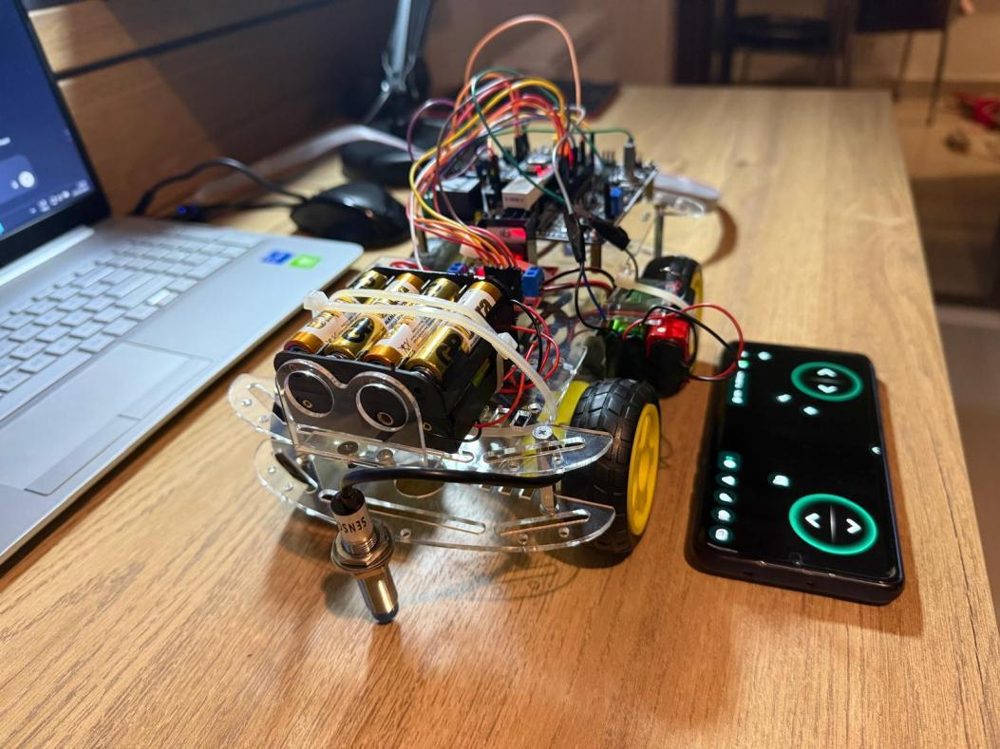
An individual term project I built in May 2025 for the Microprocessors (EEM-308) course. The goal was a remote-controlled, modular unmanned ground vehicle prototype that can find metal objects such as explosives without anyone having to enter a dangerous area.
How it works
- An STM32F103C8T6 is the main controller; four DC motors are driven through an L298N motor driver
- A phone app sends single-character commands over an HC-05 Bluetooth module (e.g. 'F' forward, 'B' back); the STM32 reads them over UART and steers the motors
- When the inductive sensor at the front detects metal, the vehicle stops on its own, an LED lights up and a buzzer sounds
- Modular add-ons: a servo that can pan a camera or an ultrasonic sensor, and a relay that switches external lighting for dark areas
- Separate power: a 12 V battery pack for the motors and a separate battery for the inductive sensor
Test results
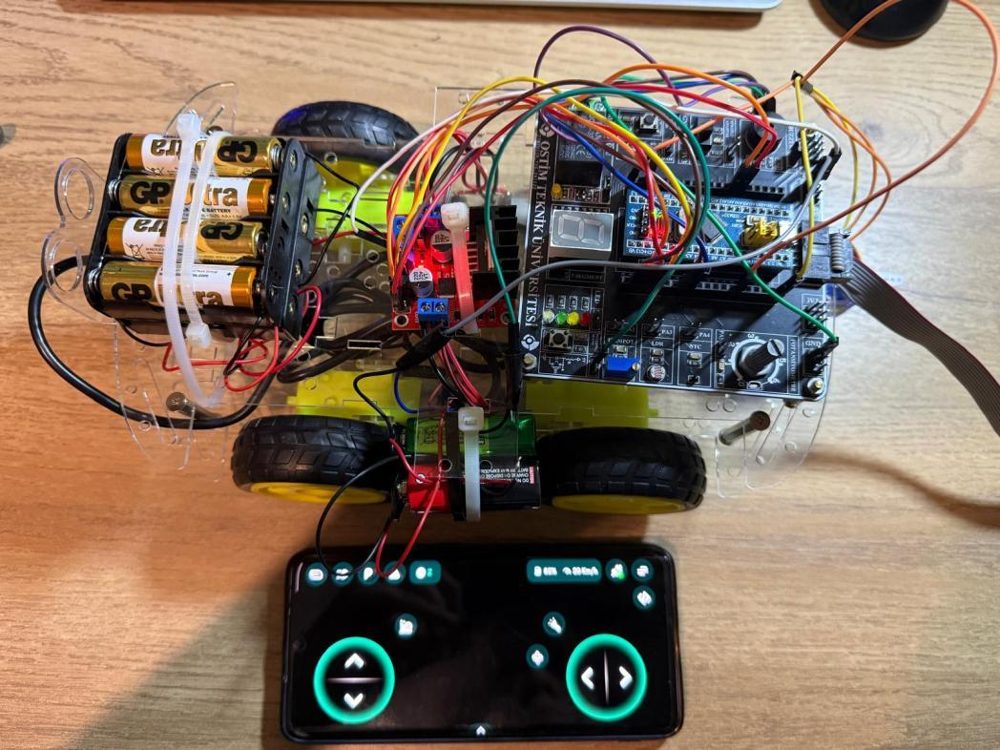
- Metal detection: sand and a wooden block were ignored; a steel screw and aluminium foil were detected and the vehicle stopped (4 out of 4 correct)
- Bluetooth command latency: 70–95 ms
- Power draw: about 850–920 mA at 12 V, roughly 10 W
Next steps
Automatic target recognition from camera images, longer range with LoRa or Wi-Fi instead of Bluetooth, autonomous route following with GPS, and a gripper to pick up suspicious objects remotely.